Wireless Charging Strategy Becomes a Fleet Design Issue as Robot Deployments Grow
- Hannah Shapiro
- 589 reads
Ben Waters says opportunity charging can keep larger robot fleets working, while battery sizing, site power and maintenance need attention early.
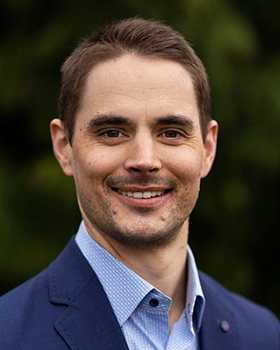
For a growing mobile robot fleet, charging strategy can affect how many hours robots stay productive, how much battery capacity they need and what electrical infrastructure a site must support. Ben Waters, CEO of WiBotic, says those questions are pushing wireless charging beyond a convenience and into the design of fleet operations.
Ben Waters, CEO of WiBotic
The change is especially visible in opportunity charging: placing wireless chargers where robots naturally pause, so they can take on energy during brief breaks instead of leaving their work area to visit a central station. Waters says the approach is becoming more relevant as deployments grow, with even fleets of 20 to 40 robots able to run into bottlenecks under a simple low-battery return-to-charge rule.
Fleet growth changes the charging calculation
Waters describes WiBotic as having expanded into adjacent markets including floor care, medical carts and space applications, where similar wireless and autonomous charging products can serve different equipment. At the same time, he says the company’s established robotics customers have seen significant volume growth. He points to automotive mobile robots, outdoor inspection at energy substations and other outdoor uses as areas of activity, with humanoid robots presenting another possible application.
For humanoids, the appeal of wireless charging is tied to uptime and the possibility of reducing time spent out of service. Waters also connects product development for humanoids with work on drone charging: both applications can benefit from systems that combine high power with low size and weight. In a humanoid, added mass increases the energy needed to balance and move the machine, while the available space for charging hardware is limited.
Opportunity charging addresses a different constraint: travel time spent getting to a charger. Under a conventional arrangement, chargers sit at fixed locations, and a robot with a low battery may have to cross a factory to reach one. During that trip it is unavailable for tasks, even if it is close to work that needs doing. Fleet management must account for both the detour and the robot’s absence from the operating area.
That simple rule can be workable at small scale. As more robots share a site, their trips to a limited set of charging points can add up to unwanted downtime and congestion. Waters says the effect can become a bottleneck even with 20 to 40 robots.
Short pauses can add energy across a shift
With opportunity charging, a charger is positioned at a place where a robot already pauses after completing a task. A stop of only 10 seconds may contribute little on its own, but repeated pauses can add a substantial amount of energy across a fleet. The intended result is for robots to stay within their normal work loops and operate for longer periods, potentially around the clock, rather than making dedicated trips to charge.
Waters argues that wireless power suits this pattern because robots may make contact with charging points frequently. A contact-based system would expose its electrical interfaces to repeated engagement, creating maintenance needs across every charger and robot in the fleet. Wireless charging avoids that contact wear. It still requires planning for charger placement and system integration, but it removes one maintenance burden that would grow with frequent connection cycles.
The operational case depends on the layout of work and pauses. A charger can only contribute during a stop if the robot reaches a suitable location and has time to use it. For fleet designers, the practical question is therefore where robots naturally wait or finish tasks, and whether charging equipment can be placed at those points without disrupting movement.
Power, batteries and maintenance belong in early planning
Waters groups early charging decisions into three areas: site power, battery sizing and maintenance. First, teams need to check where electrical outlets are located, how many are available and whether their ratings can support the planned chargers. Leaving that review until deployment can expose an infrastructure shortfall after the robot and charging systems have already been selected.
Second, charging strategy should inform battery capacity. A design that assumes an eight-hour runtime or very fast charging may call for a larger or more demanding battery than the operation requires. Battery characteristics involve trade-offs, Waters says, so a charging plan that keeps robots topped up during short pauses may change the capacity needed for a full work cycle. That can also affect battery cost, though the right choice depends on the deployment.
Fast charging deserves scrutiny on battery lifetime as well as operating speed. Waters says some customers initially ask for the fastest possible charge. When the relationship allows a closer technical discussion, WiBotic asks whether the customer has checked the battery manufacturer’s data on the effect of charging at 3°C on service life, and whether that trade-off is justified. The temperature figure is Waters’ example in the interview; battery makers’ specifications are the relevant reference for a particular pack.
Maintenance is the third design input. If teams defer decisions about infrastructure, batteries and charging hardware until robots are already being deployed, they may encounter problems within months or sooner. Considering maintenance at the outset gives designers a chance to account for service access, charger exposure and the wear associated with repeated connections.
Product development targets outdoor use and higher power
WiBotic says it aims to supply standard, supported and certified products rather than customize each system as a consulting project. Its recent addition to the 1 kW product family is an IP65-rated charger. Earlier versions of that product were offered in an IP20 black-box form factor. The IP65 option is aimed at outdoor robotics and environments such as floor care, where dust and water are part of the operating conditions.
The company is also working on smaller, lighter, high-power systems for drones and humanoids, alongside efforts to raise the output of its existing products to 3 kW. That direction reflects a shared engineering constraint: applications with limited room or strict mass limits need power delivery without adding unnecessary bulk.
As fleets expand, charging decisions increasingly shape robot availability, battery requirements and site electrical planning together. Opportunity charging offers a way to return energy during pauses already built into the work, while the choice of charge rate and hardware still needs to fit the battery and environment. The most useful time to make those trade-offs is during system design, before fleet size turns a charging detail into an operational limit.


